ORCA OS
Physical AI Operating System
Physical AI Operating System
Multi-form robots
trained together
A unified foundation for collaborative training, validation, and deployment of multi-form robots.
A unified foundation for collaborative training, validation, and deployment of multi-form robots.
Free for academic users, individual developers, and innovation teams.
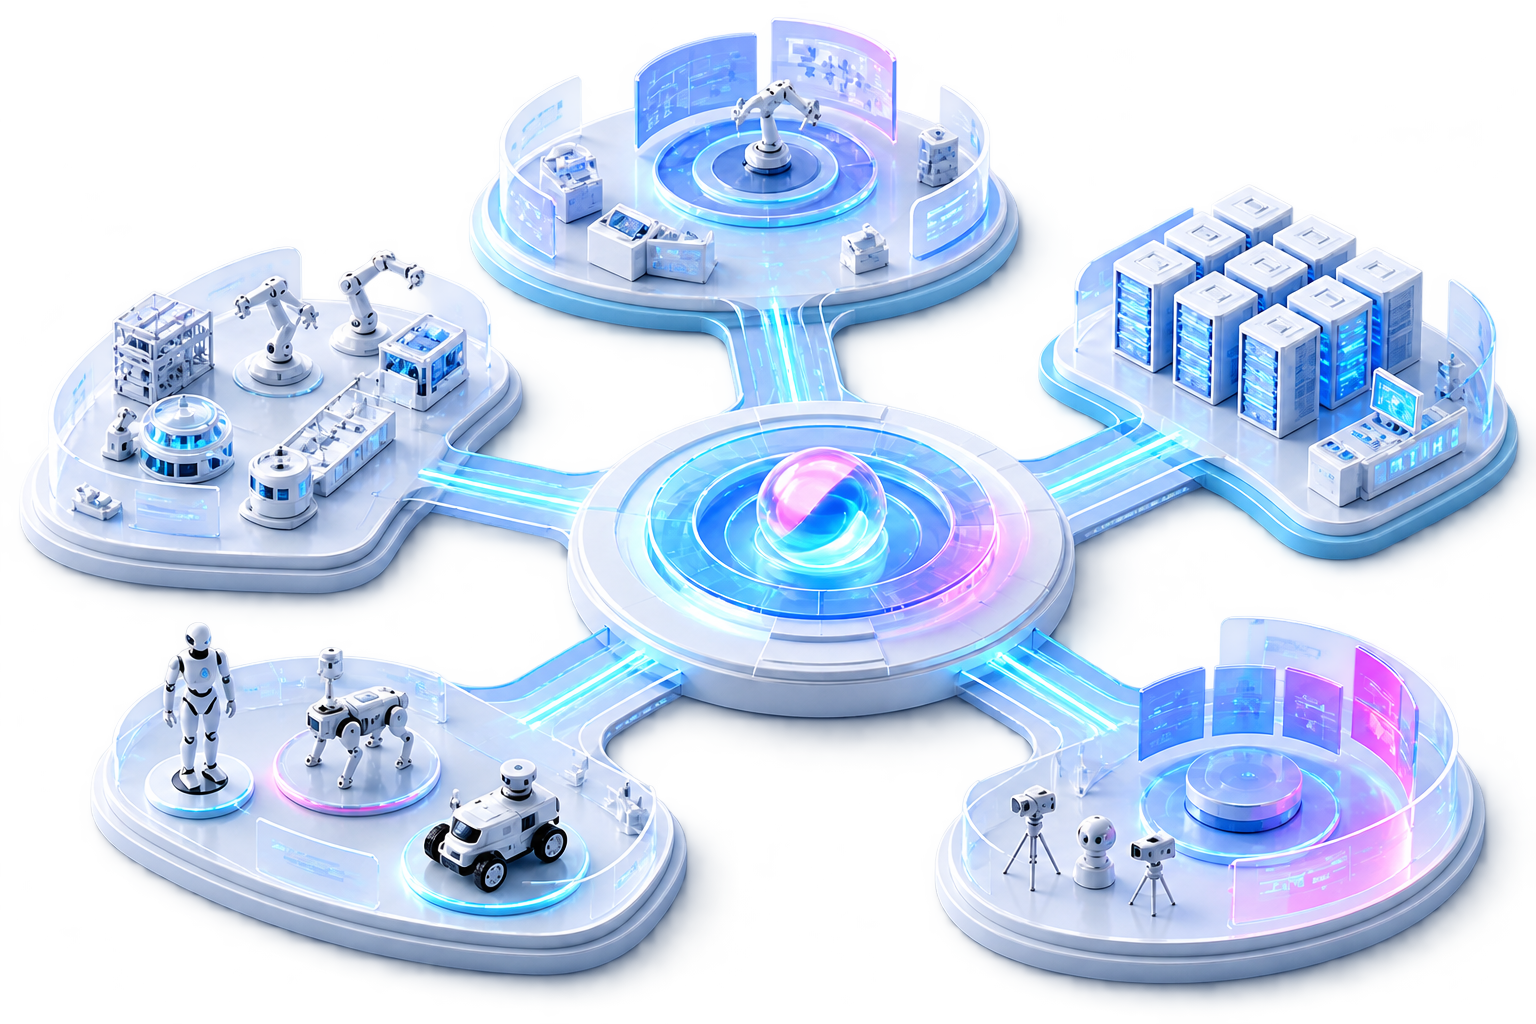
From digital training grounds to real robots — scenes, data, algorithms, training, validation, and deployment run together on one technical foundation.
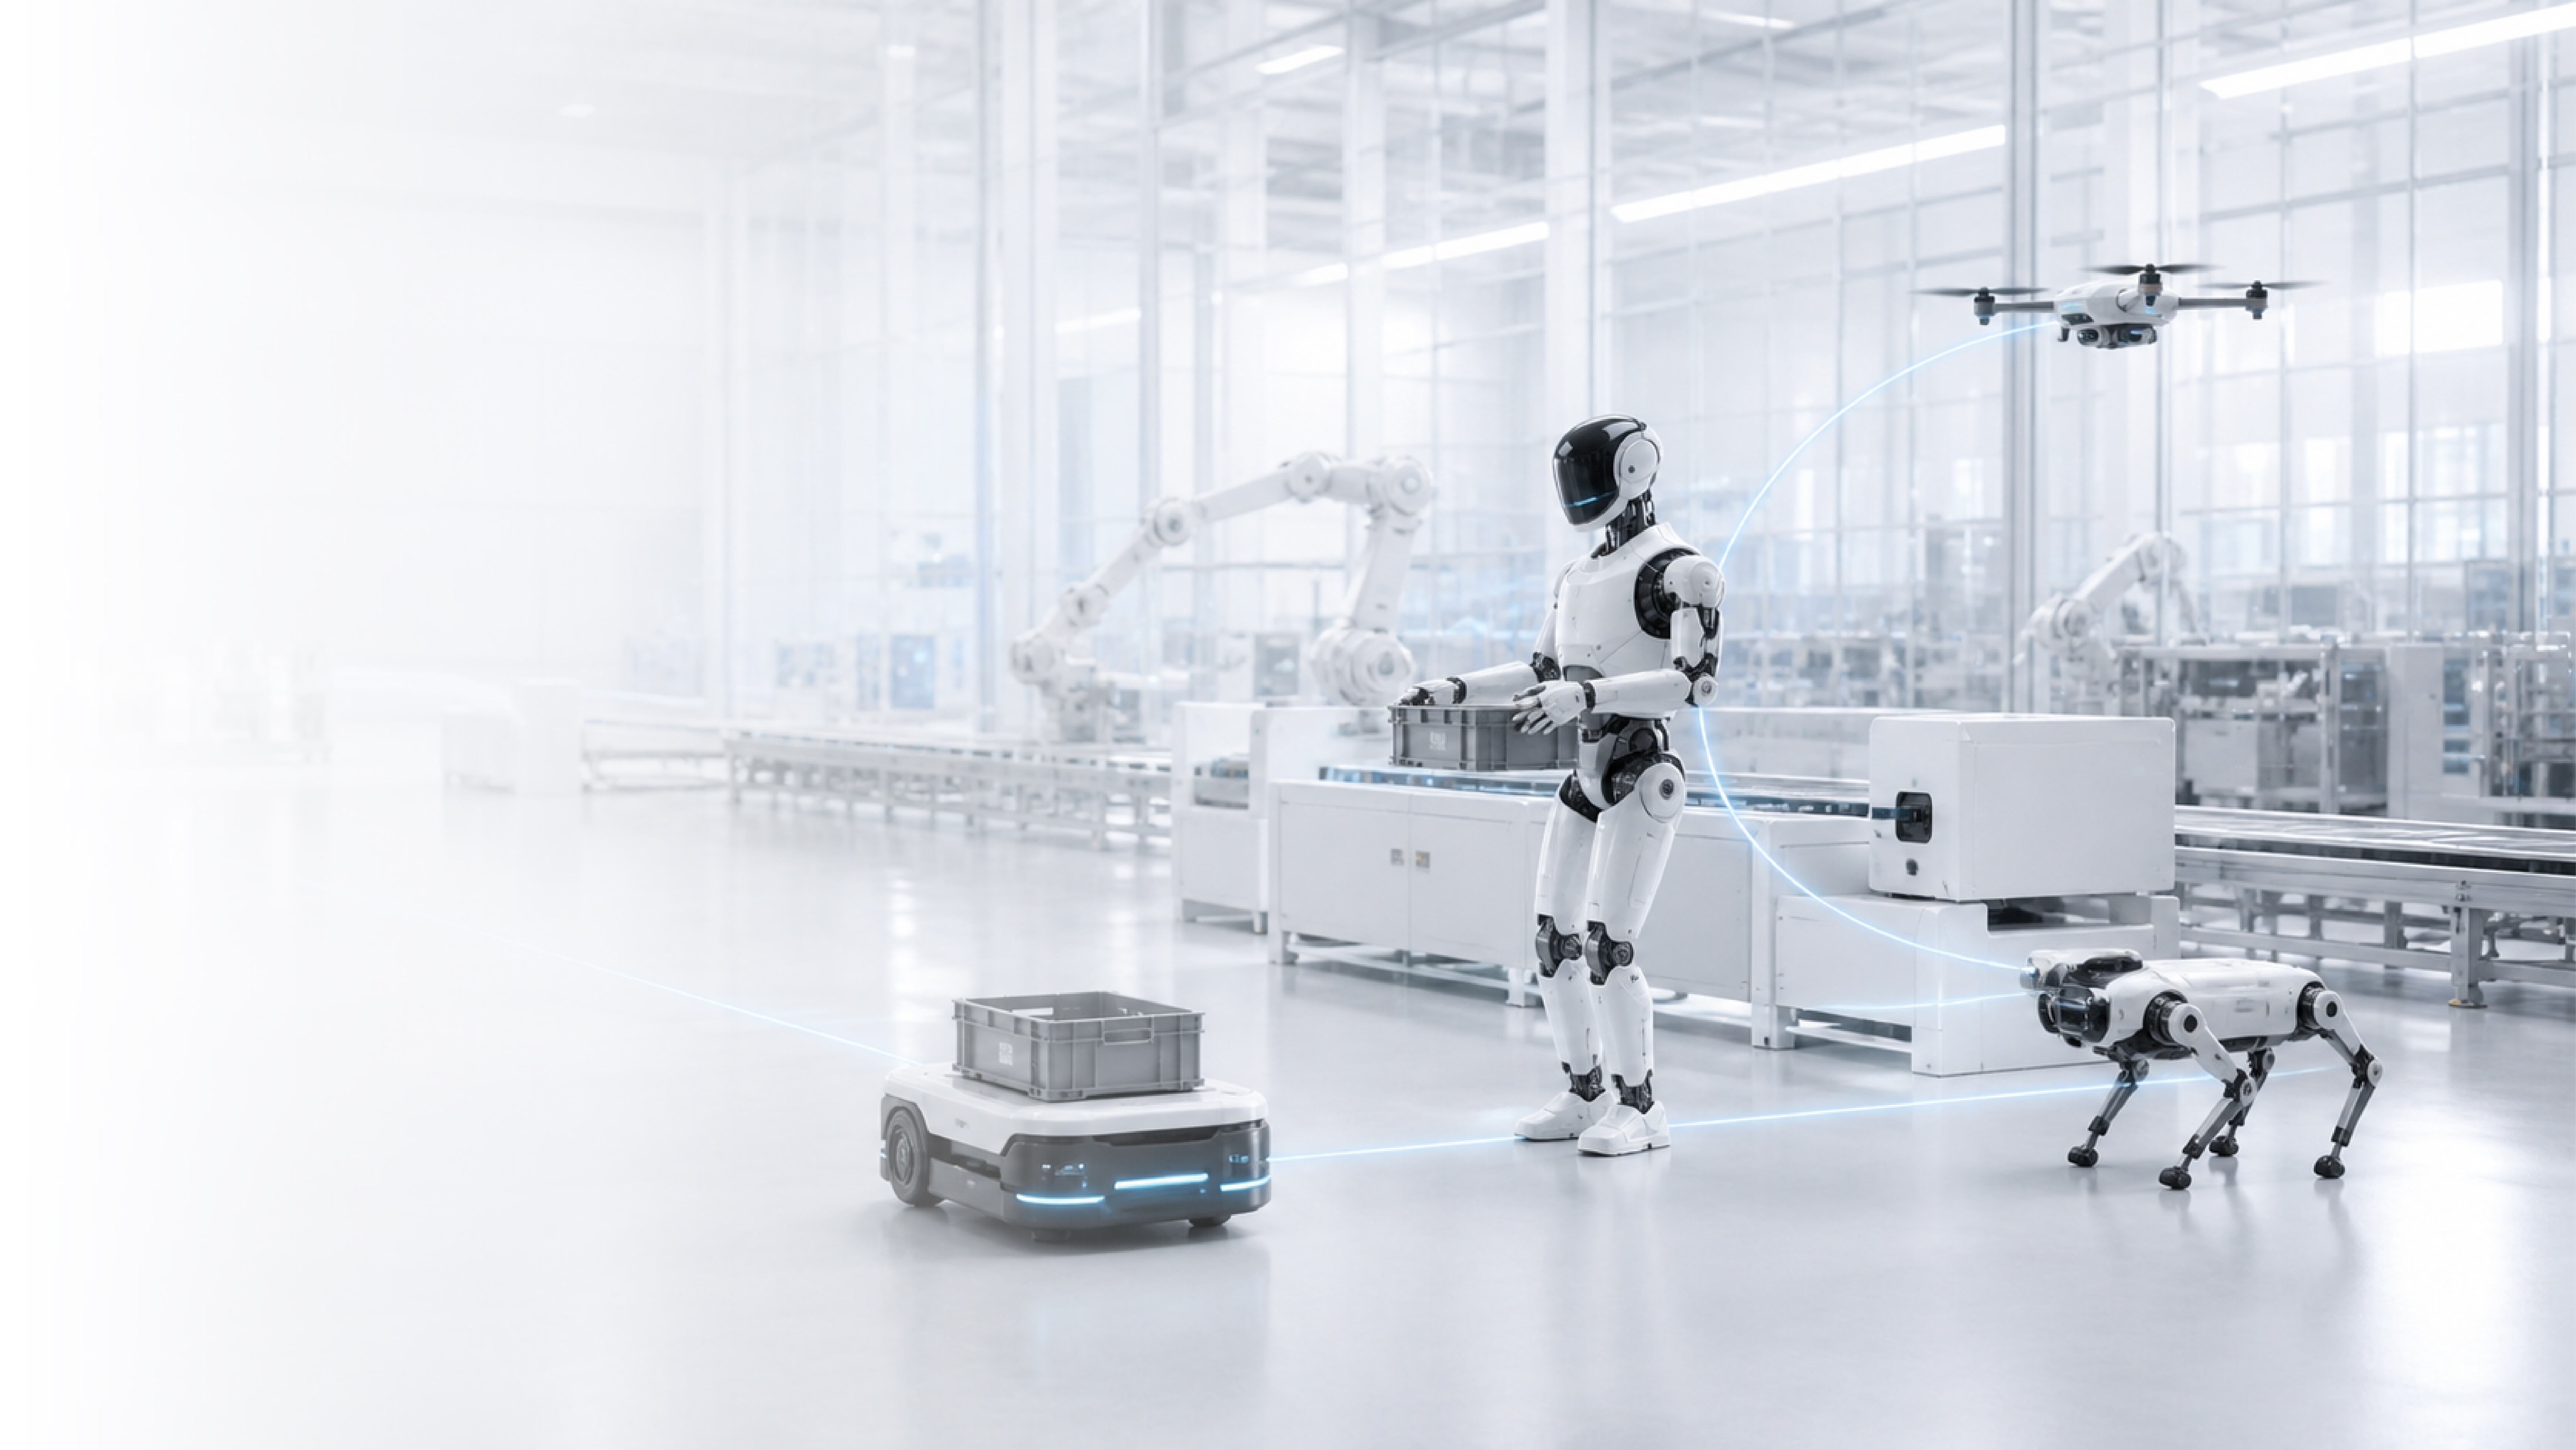
Let humanoid, quadruped, and wheeled robots and drones share scenes and state,
dynamically divide work as the environment changes, and collaborate on one task.
Built on the same ORCA OS foundation, with clear product and service entry points for every R&D stage.
Enterprise physical AI development and deployment platform.
View Details ↗02Free for academic users, individual developers, and innovation teams.
View Details ↗Integrated hardware & software, pre-installed for rapid R&D onboarding.
View Details ↗04Scene building and multimodal synthetic data services for projects.
View Details ↗05Building virtual training grounds and applications for industry clients.
View Details ↗Task training and validation for digital factories, flexible production lines, and industrial robots
Contact usCoordinating multi-robot tasks such as handling, sorting, and inspection
Contact usTraining and validation for complex, high-risk environments; power-grid operations are a key scenario
Contact usSupporting flight simulation, path planning, and low-altitude task validation
Contact usValidation for assistive care, rehabilitation training, and service robots
Contact usValidating perception, manipulation, and sequential tasks in residential environments
Contact usConnecting curriculum training, research experiments, algorithms, and prototyping
Contact usConnecting platforms, standards, compute, robots, and industry recognition to build Physical AI infrastructure together.